Need help with an order? Email technicaltriveniyt@gmail.com
Robotics

Line-Following Robot with Obstacle Avoidance and Gate (Arduino)

Build an Arduino-powered robot that follows a black line, avoids obstacles using ultrasonic sensors, and operates a gate mechanism with servos.

Intermediate3-5 hoursUpdated 14 Oct 2026
Safety first, read before building.

⚠️ LiPo Battery Warning: Use a dedicated balance charger and never leave lithium batteries charging unattended.

What you will build and learn

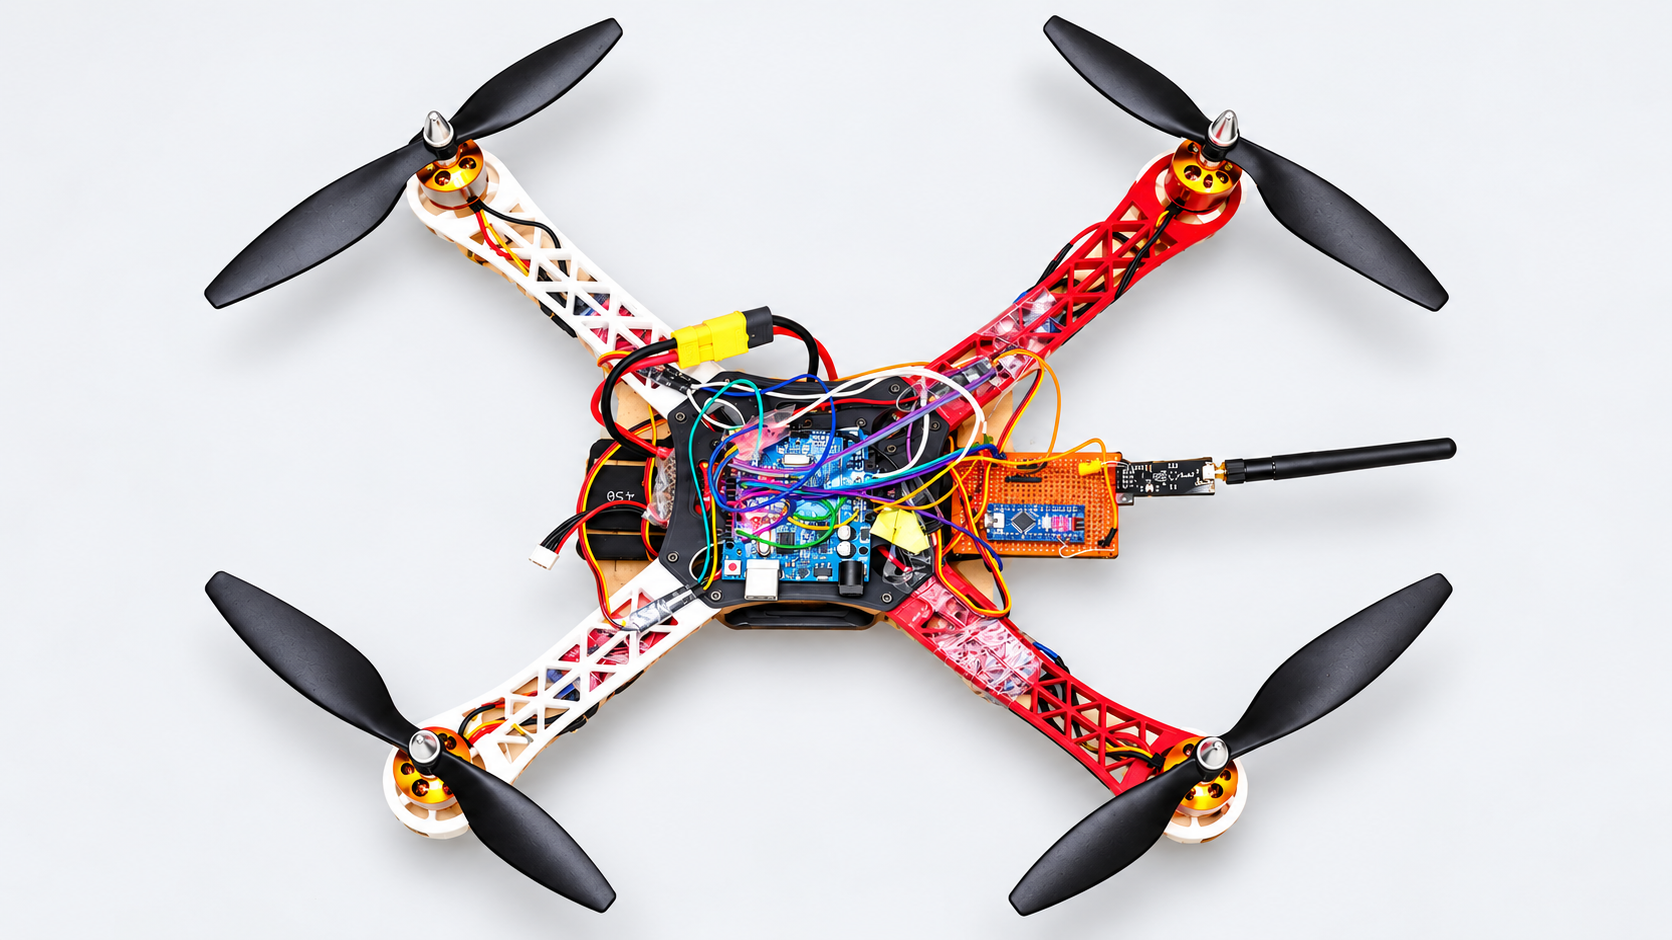
Build a custom 6-channel remote and receiver
Wire a flight controller from scratch without guessing pinouts
Learn nRF24 radio pairing and SPI diagnostics
Calibrate sensors and check motor directions safely on the bench

Prerequisites

Soldering basic wires, Arduino IDE installed on computer

What you'll build

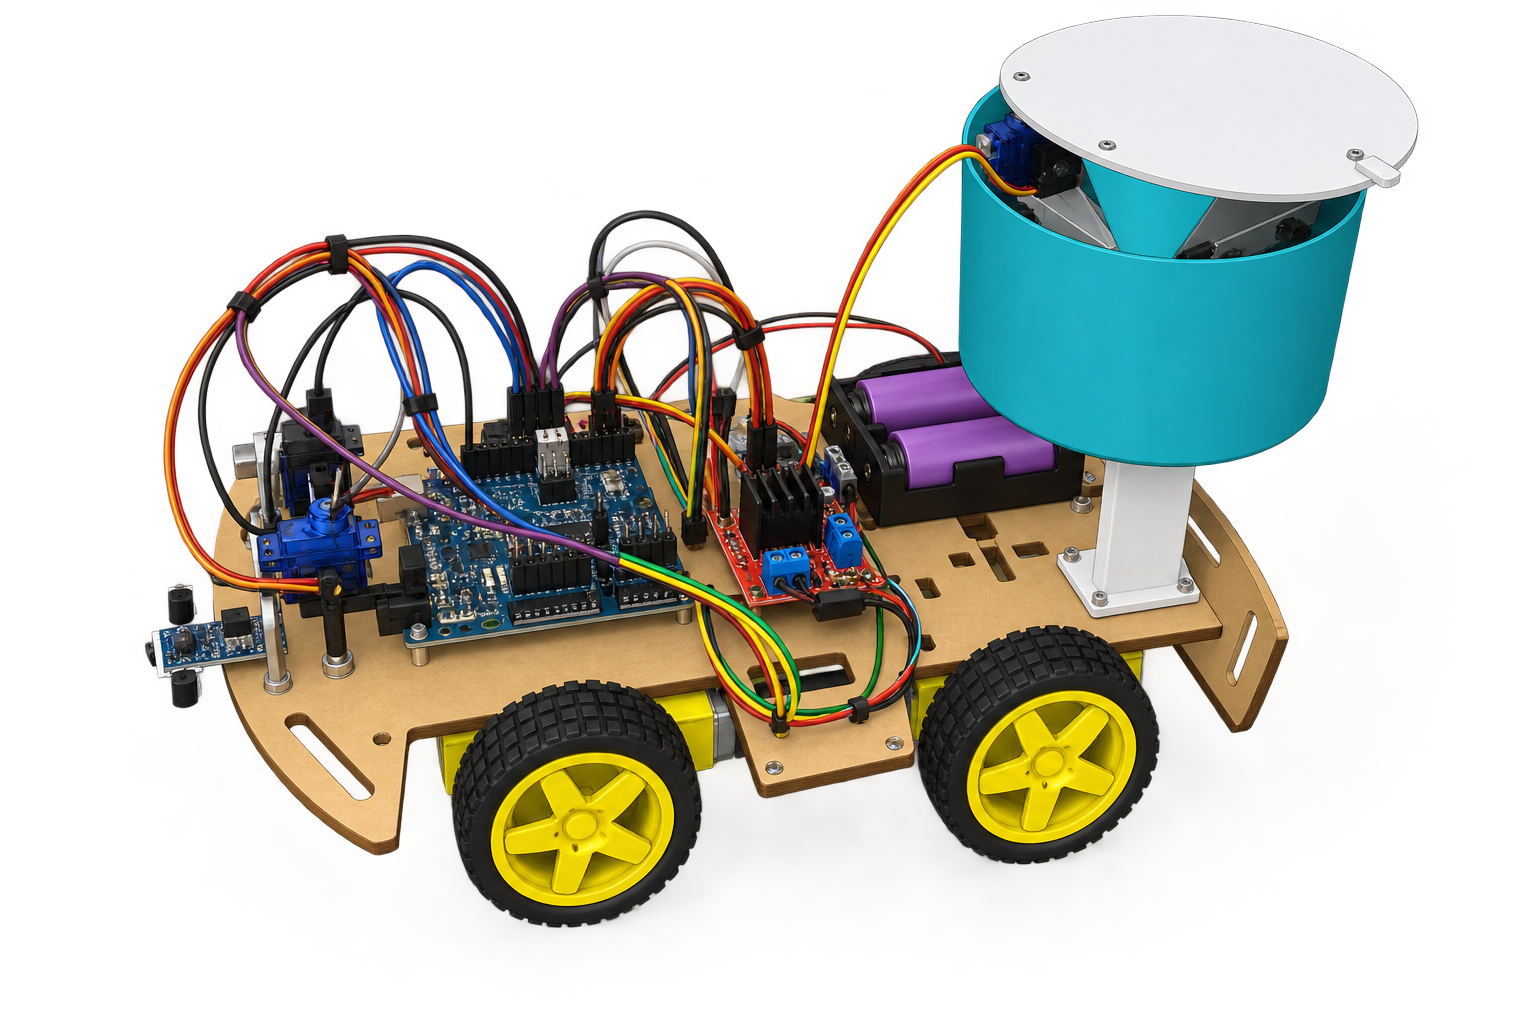
A two-wheeled robot that follows a black line on a white surface, using IR reflectance sensors. It also features an ultrasonic sensor for obstacle avoidance and two servo motors: one for scanning and another for operating a 'gate' mechanism.

How it works

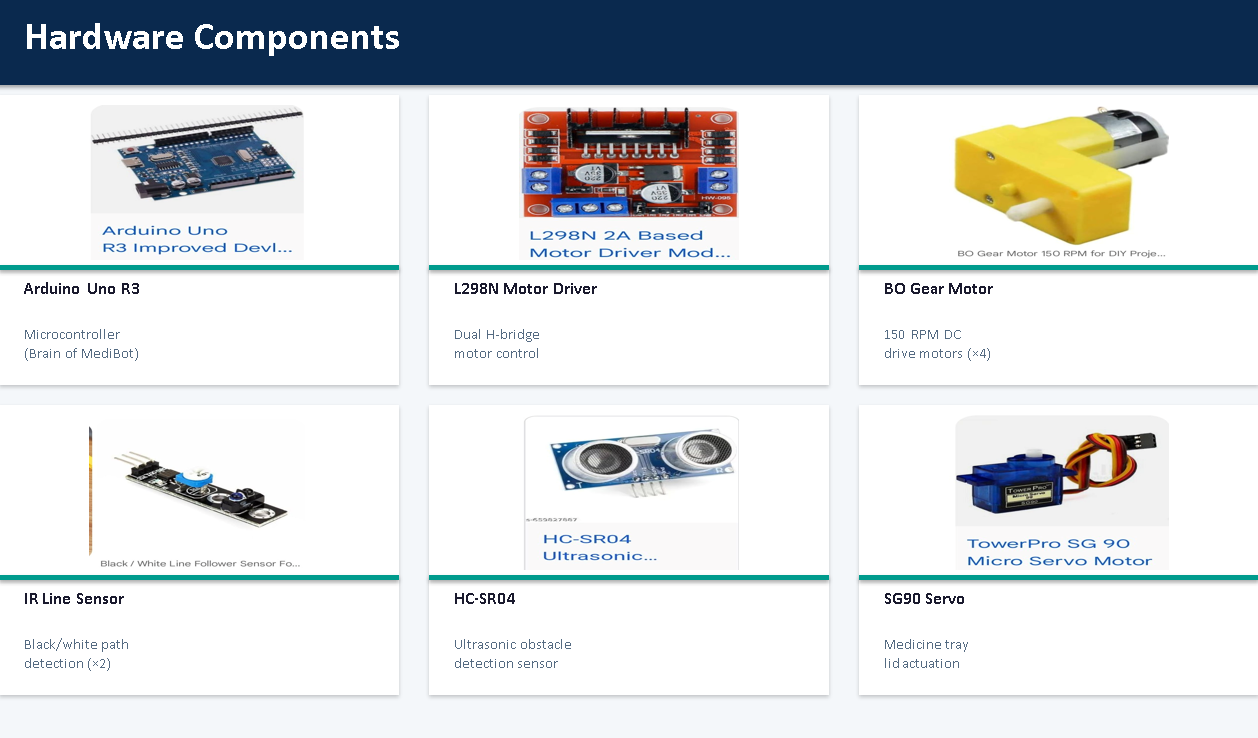
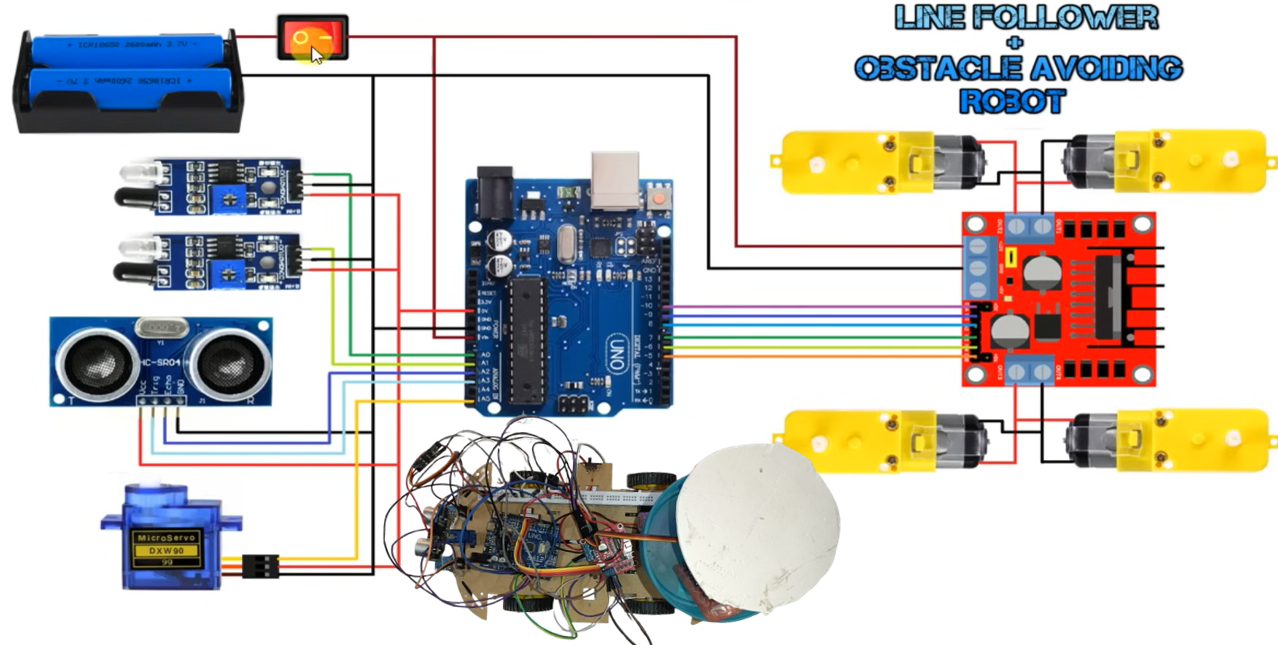
Two IR sensors detect the line edges; the Arduino processes these readings along with ultrasonic distance data to navigate. It drives the motors through an L298N driver and controls two servos for scanning and gate operations. The robot includes a calibration routine for the ultrasonic sensor and logic to stop and open a gate when both IR sensors detect black.

You'll learn

  • Reading and calibrating IR sensor arrays
  • Interfacing with ultrasonic distance sensors
  • Motor driver wiring and PWM speed control
  • Servo motor control using custom pulse generation
  • Basic robot navigation logic for line following and obstacle avoidance

Files included in this pack

PDF918 KB
code6.2 KB
License: MIT

Line-Following Robot with Obstacle Avoidance and Gate (Arduino)

Intermediate3-5 hours

Build an Arduino-powered robot that follows a black line, avoids obstacles using ultrasonic sensors, and operates a gate mechanism with servos.

Safety first, read before building.

⚠️ LiPo Battery Warning: Use a dedicated balance charger and never leave lithium batteries charging unattended.

What you will build and learn

Build a custom 6-channel remote and receiver
Wire a flight controller from scratch without guessing pinouts
Learn nRF24 radio pairing and SPI diagnostics
Calibrate sensors and check motor directions safely on the bench

Prerequisites

Soldering basic wires, Arduino IDE installed on computer

What you'll build

A two-wheeled robot that follows a black line on a white surface, using IR reflectance sensors. It also features an ultrasonic sensor for obstacle avoidance and two servo motors: one for scanning and another for operating a 'gate' mechanism.

How it works

Two IR sensors detect the line edges; the Arduino processes these readings along with ultrasonic distance data to navigate. It drives the motors through an L298N driver and controls two servos for scanning and gate operations. The robot includes a calibration routine for the ultrasonic sensor and logic to stop and open a gate when both IR sensors detect black.

You'll learn

  • Reading and calibrating IR sensor arrays
  • Interfacing with ultrasonic distance sensors
  • Motor driver wiring and PWM speed control
  • Servo motor control using custom pulse generation
  • Basic robot navigation logic for line following and obstacle avoidance
FreeOne-time, instant access